NexArm LeRobot 6-Axis AI Robotic Arm – ESP32 Open-Source Robot for VLA, Imitation Learning & Embodied AI
-
【Embodied Al Robotic Arm】NexArm robot arm features an industrial-grade metal body with high-precision magnetic encoder servos and inverse kinematics. It delivers a 500mm reach,500g payload, and +2mm repeatability. Curve smoothing algorithms eliminate jitter for precise grasps and smooth trajectories.
-
【Compatibility with the LeRobot Ecosystem & End-to-End Algorithms】NexArm robotic arm is fully integrated with the LeRobot framework to access community models, datasets, and simulations. Developers can easily train and deploy end-to-end imitation and reinforcement learning algorithms like ACT.
-
【Leader-Follower Teleoperation & VLA Development】Supports synchronous teleoperation via leader and follower arms. By capturing HD video alongside trajectory data, NexArm robotic arm quickly builds "vision-action" datasets, making it an ideal platform for VLA (Vision-Language-Action) model training.
-
【Dual-Camera Vision System】Equipped with both a gripper-mounted camera and an external camera, the robot arm system supports both precise manipulation and environmental awareness for accurate imitation learning.
-
【Open-Source and Multi-Mode Control】Open-source code and schematics, plus PC software, app control, secondary development examples, and structured tutorials, significantly lower the barrier to embodied AI development.


Product Description
NexArm is an open-source AI robotic arm platform built for embodied AI and VLA (Vision-Language-Action) learning. Featuring an industrial-grade, all-metal housing, high-precision magnetic encoder serial bus servos, dual-output shaft power joints, and in-house motion control algorithms, it delivers a stable, reliable hardware foundation for robot learning.
NexArm covers the complete development pipeline, from teleoperation teaching and data collection to imitation learning and edge deployment. Fully compatible with the LeRobot ecosystem, it enables rapid deployment of cutting-edge robot policies like ACT, Diffusion Policy, and Pi0.

Built for Imitation Learning
Supports a leader-follower teleoperation system composed of a leader arm and a follower arm, with deep compatibility at the underlying level with the latest Hugging Face LeRobot framework.

Seamless Hugging Face Ecosystem Integration
The leader arm uses a 1:147 gear ratio for high-frequency demonstration capture, while the follower arm uses a 1:345 reduction ratio for superior positioning stability. This enables smooth access to Hugging Face community models for end-to-end imitation learning.

High-Precision Magnetic Encoder Bus Servo
Built around a dual-output-shaft magnetic encoder servo system with all-metal gears. A powerful magnetic motor and real-time feedback from multiple algorithms ensure precise and stable joint movement.

Parallel-Rail Gripper
Silicone gripper pads and stainless-steel transmission components ensure asecure grip and improved durability.


Cross-Platform Control and Connectivity


App Control
Through the app, each NexArm joint can be controlled independently. Designated objects can also be grasped and sorted with flexible control, while preset action groups can be called up quickly.

Offline Drag Teaching
The leader arm can be dragged offline for intuitive demonstration. Combined with advanced imitation learning algorithms, the follower arm can accurately reproduce motion and grasping trajectories.

Wireless Multi-Device Control
Supports multilingual remote collaboration across multiple devices, with unicast, multicast, and broadcast modes. Automated scenarios can be deployed with ease, helping build a highly responsive AIoT collaborative ecosystem.
Wireless Controller Control
Equipped with a PS3 wireless controller and low-latency one-to-one pairing, allowing multiple devices to run side by side without interference. Programming support also enables different feedback actions on NexArm.
High-Performance Hardware


Specification Parameters


| Product Parameters | ||
| Brand | Hiwonder | |
| Product name | NexArm open-source embodied AI robotic arm | |
| Material | Metal frame | |
| Dimensions | Leader arm: 111 × 216 × 619 mm | Follower arm: 111 × 111 × 614 mm |
| Weight | Leader arm: 1.2 kg | Follower arm: 1.3 kg |
| Servos | Leader arm: HX-10HM × 5 + HX-12H × 1 | Follower arm: HX-12H × 2 + HX-30HM × 3 + HX-65HM × 1 |
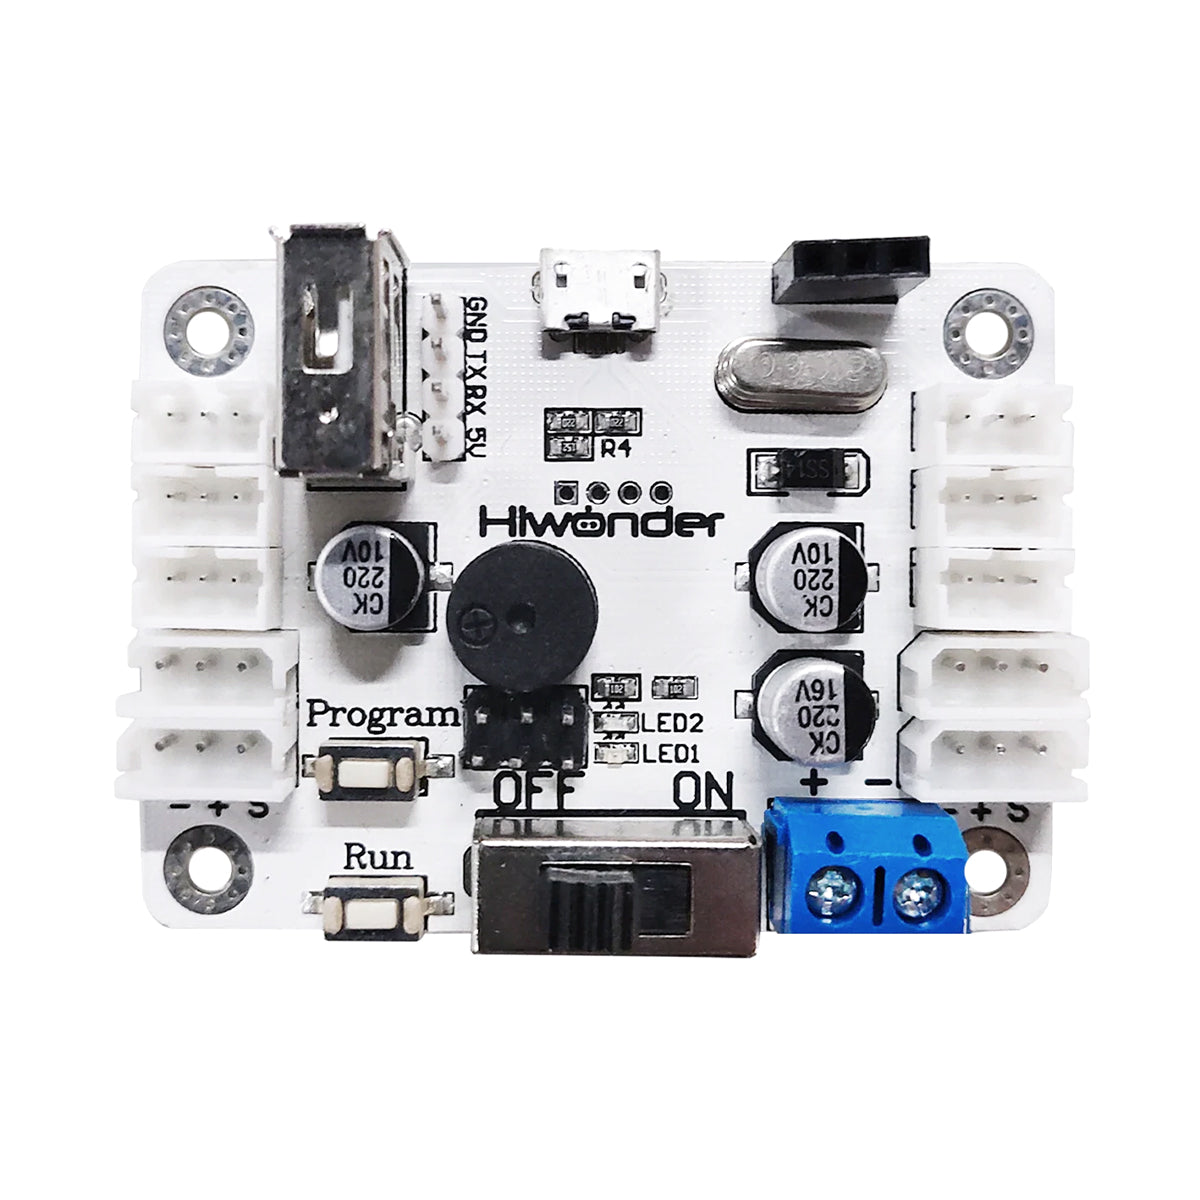
| Controller | NexArm follower arm controller, NexArm leader arm controller | |
| Power supply | 12V 5A (DC 5.5 × 2.5) | |
| Operating system | Windows / Linux / macOS | |
| Control method | USB serial / Bluetooth / Wi-Fi | |
| Programming tool | Arduino IDE | |
| Package weight & dimensions | Leader Arm: 3.2kg, 345 × 158 × 220 mm Follower Arm: 2.9kg, 345 × 158 × 220 mm Standard Kit: 6.7kg, 487 × 290 × 195 mm Advanced Kit: 7.9kg, 487 × 290 × 195 mm |
|


Videos
What is NexArm? >>>
🤖 NexArm dual-arm teleop with sparkling water >>>
Blog

《Smooth Mastery: NexArm Redefines Motion Aesthetics for Desktop Robotic Arms》

《Decoding the Secret Behind NexArm's Silky‑Smooth Motion》
| Item | Specification | |
| Brand | Hiwonder | |
| Product name | NexArm open-source embodied AI robotic arm | |
| Material | Metal frame | |
| Dimensions | Leader arm: 111 × 216 × 619 mm | Follower arm: 111 × 111 × 614 mm |
| Weight | Leader arm: 1.2 kg | Follower arm: 1.3 kg |
| Servos | Leader arm: HX-10HM × 5 + HX-12H × 1 | Follower arm: HX-12H × 2 + HX-30HM × 3 + HX-65HM × 1 |
| Controller | NexArm follower arm controller, NexArm leader arm controller | |
| Power supply | 12V 5A (DC 5.5 × 2.5) | |
| Operating system | Windows / Linux / macOS | |
| Control method | USB serial / Bluetooth / Wi-Fi | |
| Programming tool | Arduino IDE | |
| Package weight & dimensions | Leader Arm: 3.2kg, 345 × 158 × 220 mm Follower Arm: 2.9kg, 345 × 158 × 220 mm Standard Kit: 6.7kg, 487 × 290 × 195 mm Advanced Kit: 7.9kg, 487 × 290 × 195 mm |
|
Shipping & Delivery
1. Free Shipping Policy
Hiwonder offers free standard shipping on orders over US $499 (before tax and duties), delivered via trusted carriers such as DHL, UPS, or FedEx.
Most orders arrive within 6 working days after dispatch. You can check if your country is eligible for free shipping in the regions listed below.
Eligible Regions
- Americas: United States, Canada, Mexico, Chile
- Europe: Germany, United Kingdom, Netherlands, Switzerland, France, Austria, Italy, Belgium, Spain, Sweden, Finland, Norway, Portugal, Czech Republic, Poland, Greece, Slovenia, Romania, Denmark, Bulgaria, Luxembourg, Slovakia, Hungary, Ireland, Estonia, Lithuania
- Asia: China, Japan, Singapore, South Korea, United Arab Emirates, Malaysia, Thailand, Philippines, Indonesia
- Oceania: Australia, New Zealand
If your country or region is not listed above, the shipping cost will be automatically calculated at checkout once you enter your shipping address.
2. Customs & Import Fees
All international shipments are subject to local customs regulations. Import duties, taxes, or other fees may be charged by your country's customs authority upon arrival.
Our shipping term is FOB Shenzhen, which means these fees, if any, are the customer's responsibility. The shipping carriers will assist with the customs clearance process to ensure smooth delivery.
If a package is returned due to unpaid customs duties, any related return or reshipping fees will be deducted from your refund.
3. Order Processing Time
Orders are typically processed within 24 hours after placement and shipped the next business day.
Orders placed on weekends or public holidays will be shipped on the next working day.
Once shipped, you will receive a confirmation email with tracking information.